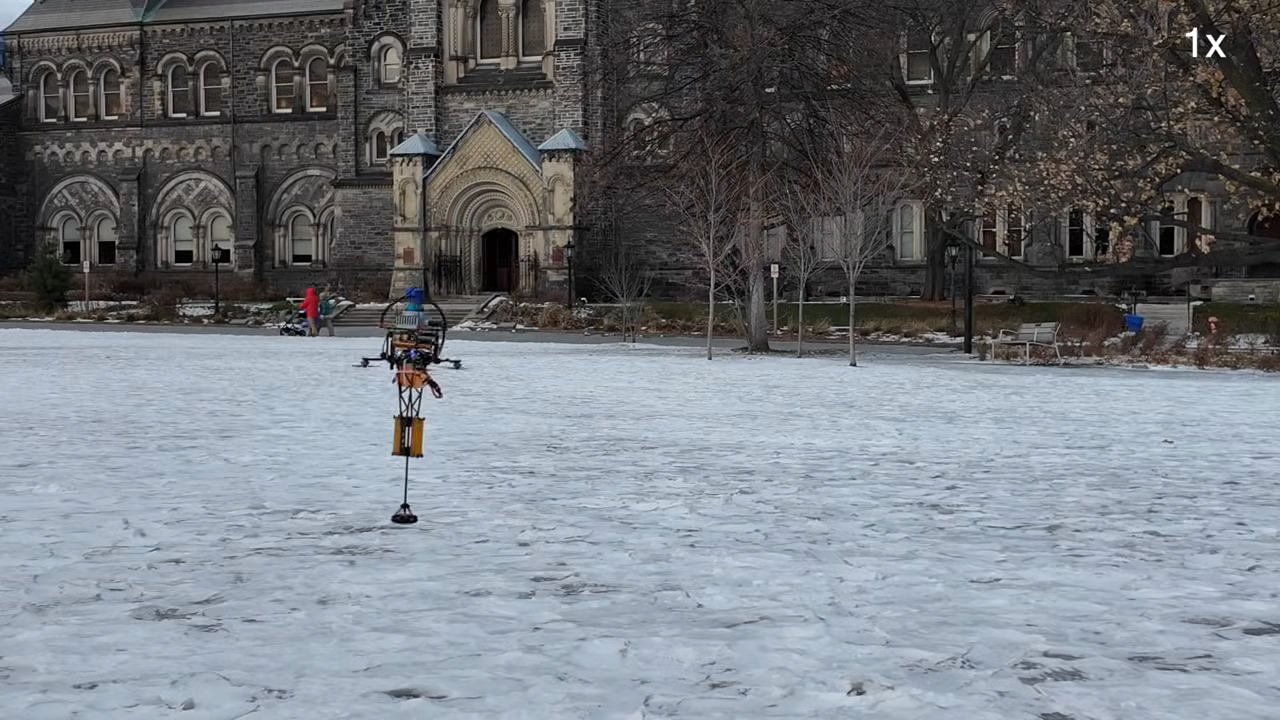
Pogo-Bot Goes All Terrain With Compliant Foot
Researchers at the University of Toronto have developed a monopedal hopping robot that combines quadcopter propulsion with a spring-loaded single leg featuring a compliant, pivoting foot pad. The design allows the robot to maintain stability and traction across diverse terrains including sand and ice, improving upon earlier spike-based designs that proved unreliable.